Best Presentation · AWARE-AI Fall Hackathon 2026
Drive a robot with one forearm
A Myo armband reads your arm like a lever: its angle sets speed and steering, and a firm fist brakes.
What we built
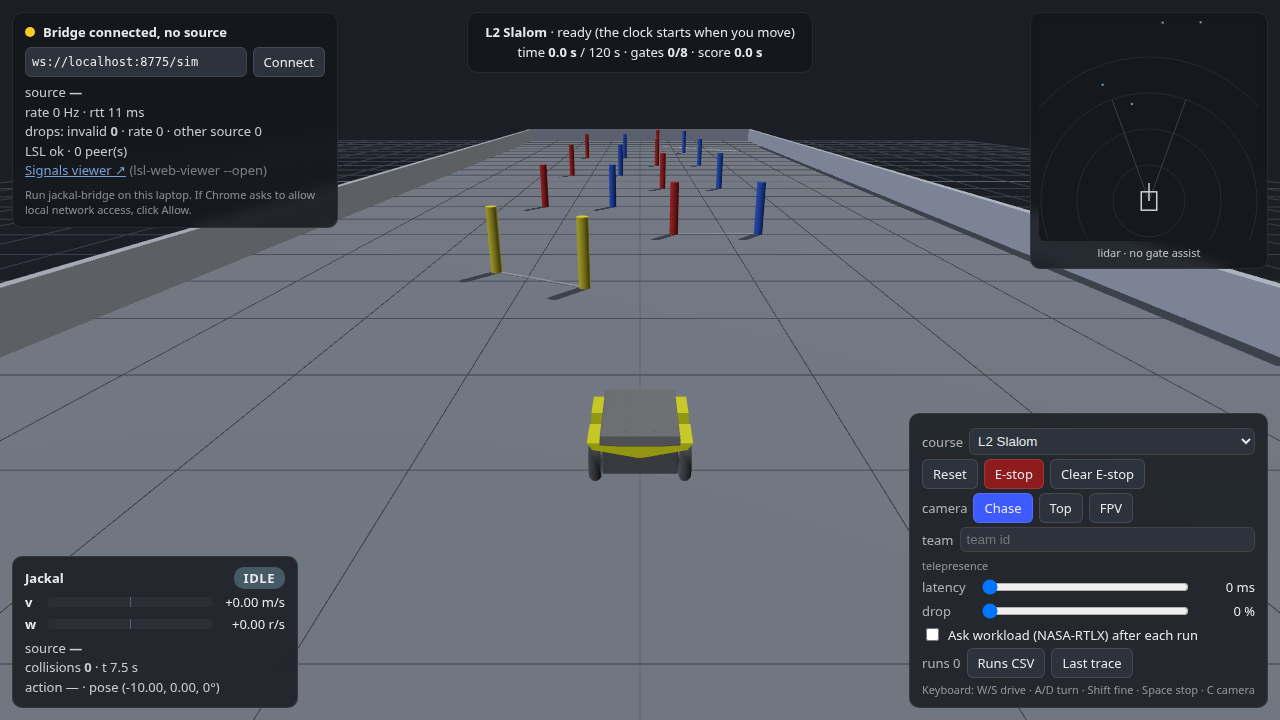
Our team's entry to the AWARE-AI Fall Hackathon at RIT, October 22-23, 2026. Every team got the same browser sim of a Clearpath Jackal, a command bridge and a Myo armband. The task: turn the armband's signals into forward speed and turn rate, drive three timed courses, then keep the robot drivable over a slow, lossy link.
We started with five muscle gestures and a classifier, and it broke as soon as the forearm rolled. So the controller steers with the armband's motion sensor, which rolling cannot fool, and keeps the muscle signal for one job: a deliberate fist that brakes. A lidar assist slows before obstacles and nudges you through a gate you are already aimed at.
What it did
20.7 s L1 Gates, median of 4 runs, 0 collisions
26.6 s L2 Slalom, median of 6 runs, 0 collisions
16.3 s L3 Corridor + Dock, median of 4 runs, 0 collisions
All 51 recorded runs finished with no missed gates. A new driver calibrates in about 2.5 minutes with one command. All the results, including what did not work →
The team
AJ Barea, Jose, Kiran and Xinyi Liu. Xinyi built the gate assist, the sim's lidar minimap, the assist viewer and the pooled brake model; AJ wrote the lever controller, the neural-network study and the deck generator. The sim, the bridge and the event kit come from the organizers' AHRTLab/Hackathon repo, which ours forks.