Best Presentation · AWARE-AI Fall 2026 Hackathon
Drive a robot with one forearm
A Myo armband reads your arm like a lever: its angle sets speed and steering, and a firm fist brakes.
What we built
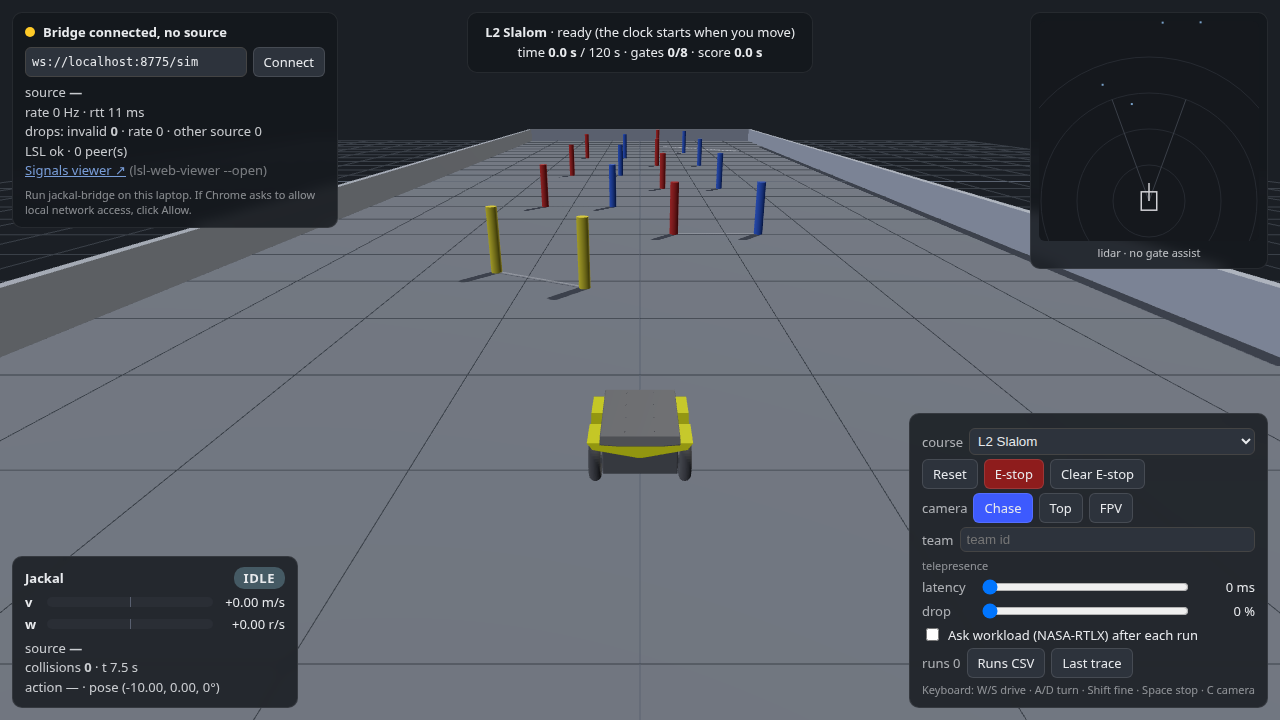
Our team's entry to the AWARE-AI Fall 2026 Hackathon at RIT, October 22-23. Every team got the same browser sim of a Clearpath Jackal, a command bridge and a Myo armband. The task: turn the armband's signals into forward speed and turn rate, drive three timed courses, then keep the robot drivable over a slow, lossy link.
We started with five muscle gestures and a classifier, and it broke as soon as the forearm rolled. So the controller steers with the armband's motion sensor, which rolling cannot fool, and keeps the muscle signal for one job: a deliberate fist that brakes. A lidar assist slows before obstacles and nudges you through a gate you are already aimed at.
What it did
20.7 s L1 Gates, median of 4 runs, 0 collisions
26.6 s L2 Slalom, median of 6 runs, 0 collisions
16.3 s L3 Corridor + Dock, median of 4 runs, 0 collisions
All 51 recorded runs finished with no missed gates. A new driver calibrates in about 2.5 minutes with one command. All the results, including what did not work →
The team
AJ Barea, Jose, Kiran and Xinyi Liu. AJ led development and data collection with Claude Code, wrote the lever controller, the neural-network study and the deck generator, and published both dataset releases. Xinyi built the gate assist, the sim's lidar minimap, the assist viewer and the pooled brake model. Jose, Kiran and Xinyi recorded the calibrations for the four-driver study. The sim, the bridge and the event kit come from the organizers' AHRTLab/Hackathon repo, which ours forks.